Recognized as a Top Reviewer at NeurIPS 2026.
Keyan Miao
I'm currently a postdoctoral researcher in Intelligent Control Systems at ETH Zurich, working with Prof. Melanie Zeilinger.
I completed my DPhil in Engineering Science at the University of Oxford in 2026, where I was a member of the Control Engineering Group, supervised by Prof. Antonis Papachristodoulou and Dr. Konstantinos Gatsis. Before that, I obtained an MSc in Control Systems from Imperial College London, supervised by Prof. Richard Vinter, and a BEng in Detection, Guidance and Control from Northwestern Polytechnical University. Outside academia, I play the violin and enjoy photography.
Building reliable learning systems through control-theoretic insight.
News
MoreJoined ETH Zurich as a postdoctoral researcher, working with Prof. Melanie Zeilinger.
My episode, Interfacing Control with Neural ODEs, is now available on the Coffee and Control podcast.
Paper Accelerating Neural Network Training with Augmented Koopman Dynamics accepted by NeurIPS 2026.
Paper PLATO: Preintegration Learning from Accurate Trajectory Observations for Neural Inertial Odometry accepted by CoRL 2026.
Received an EPSRC Pathway Postdoctoral Fellowship.
Received an ICML 2026 Gold Reviewer Award.
Attended the 14th International Conference on Learning Representations (ICLR) in Rio de Janeiro, Brazil.
I successfully defended my DPhil thesis!
Gave a talk on Efficient and Reliable AI at ETH AI Center Fellowship Symposium.
Research
More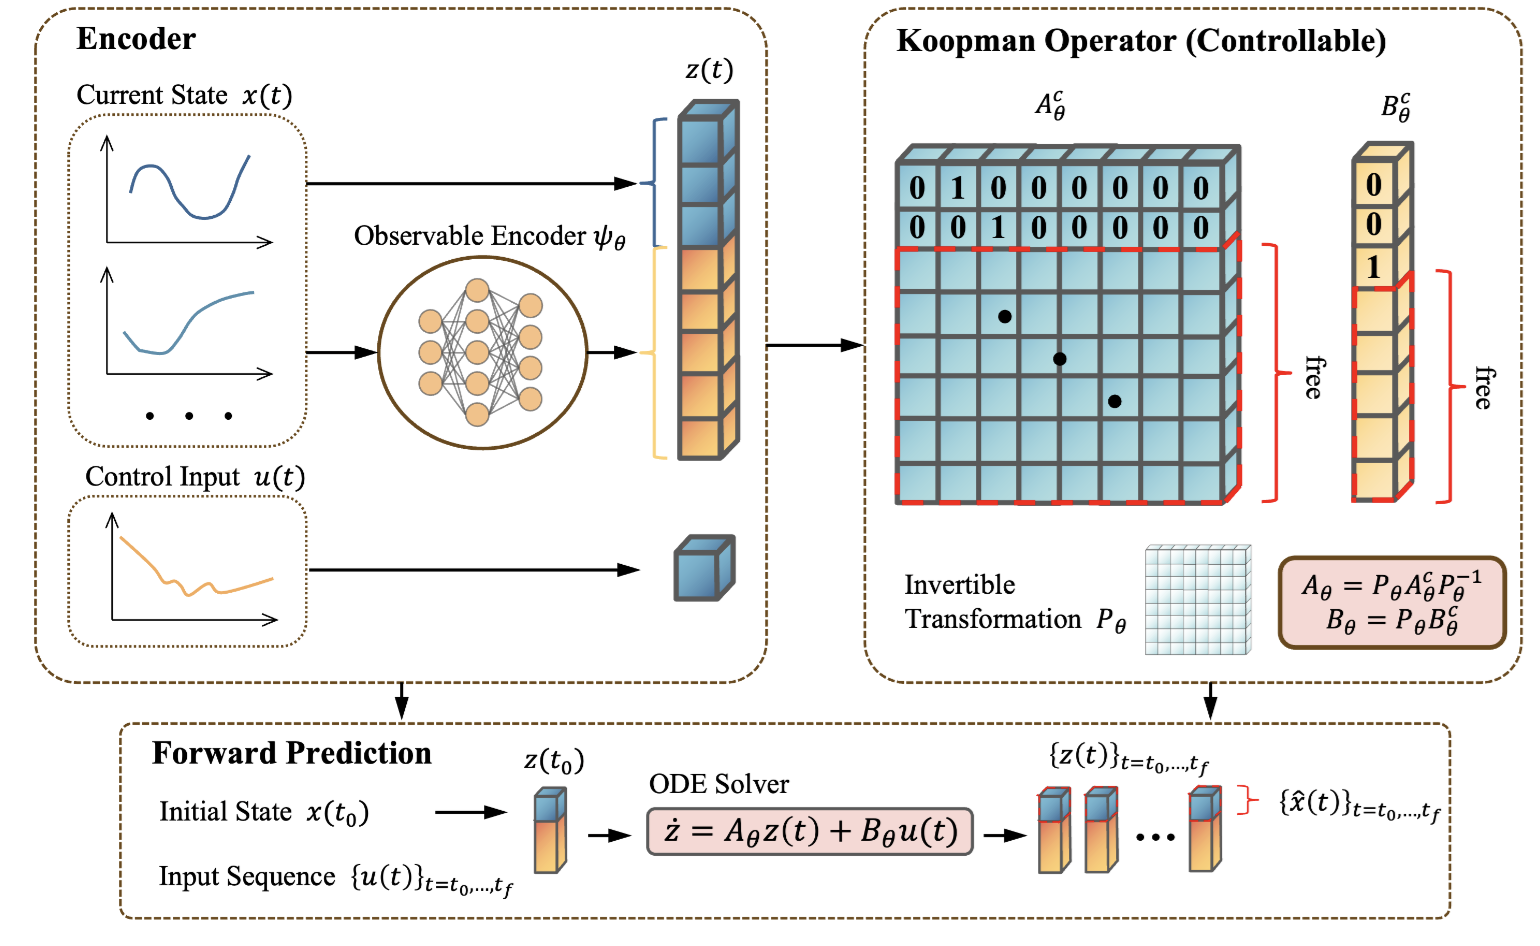 01
Learning With Constraints/Guarantees
Building constraints, structure, and formal guarantees directly into learning.
 02
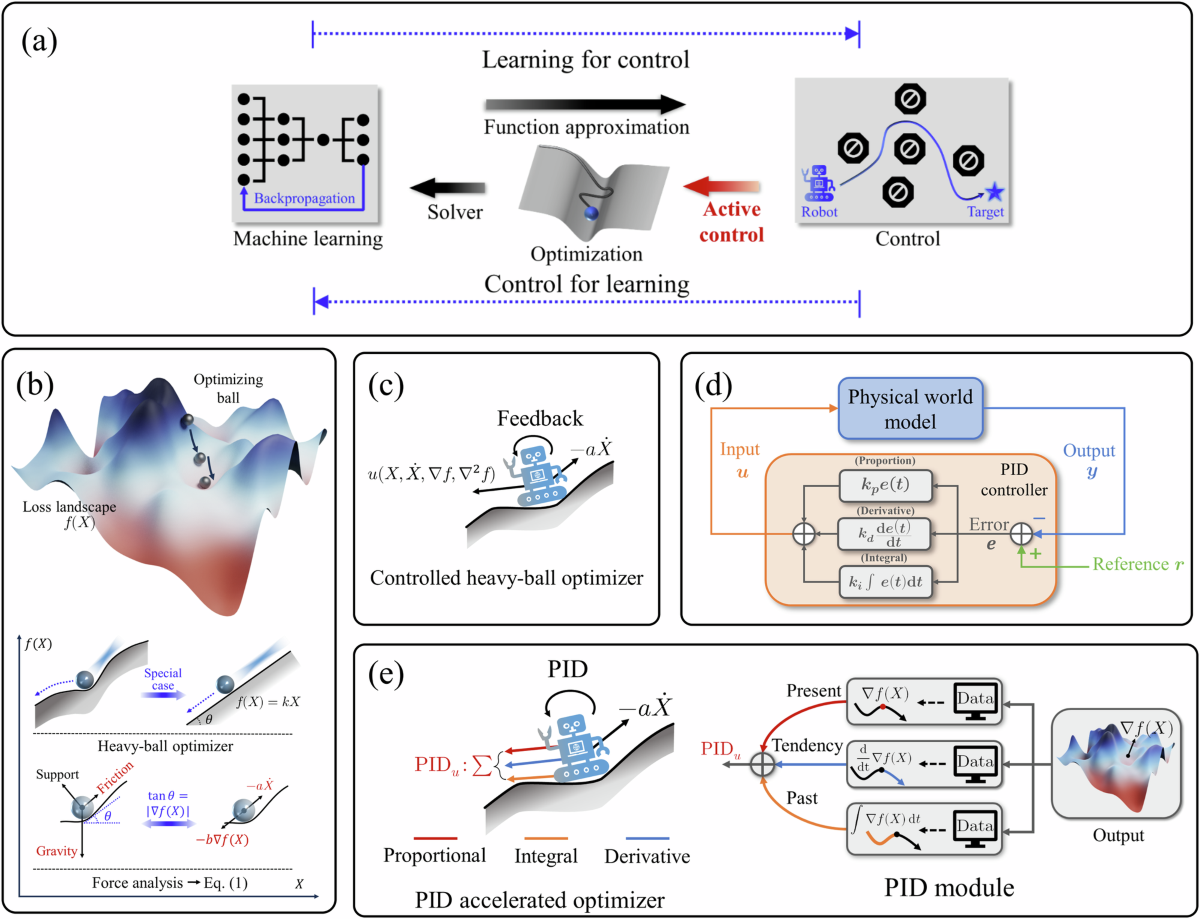
Control-Informed Machine Learning
Using control perspectives to understand and improve learning models, training, and optimization.
 03
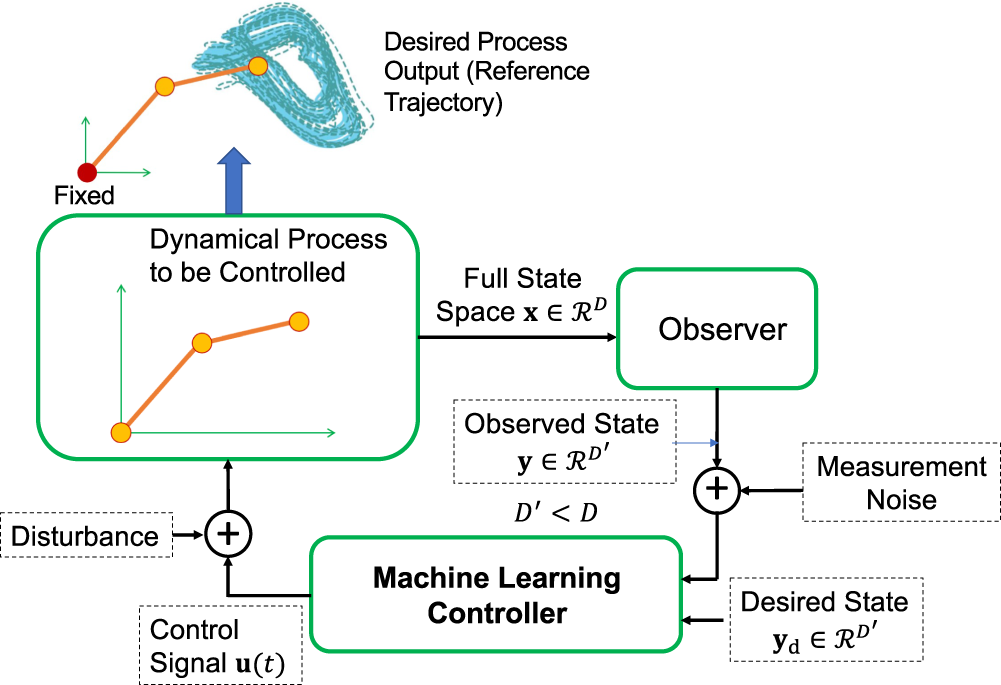
Learning-Based Control
Integrating learning with modeling, estimation, prediction, and control of dynamical systems.
Publications from Google Scholar
All publications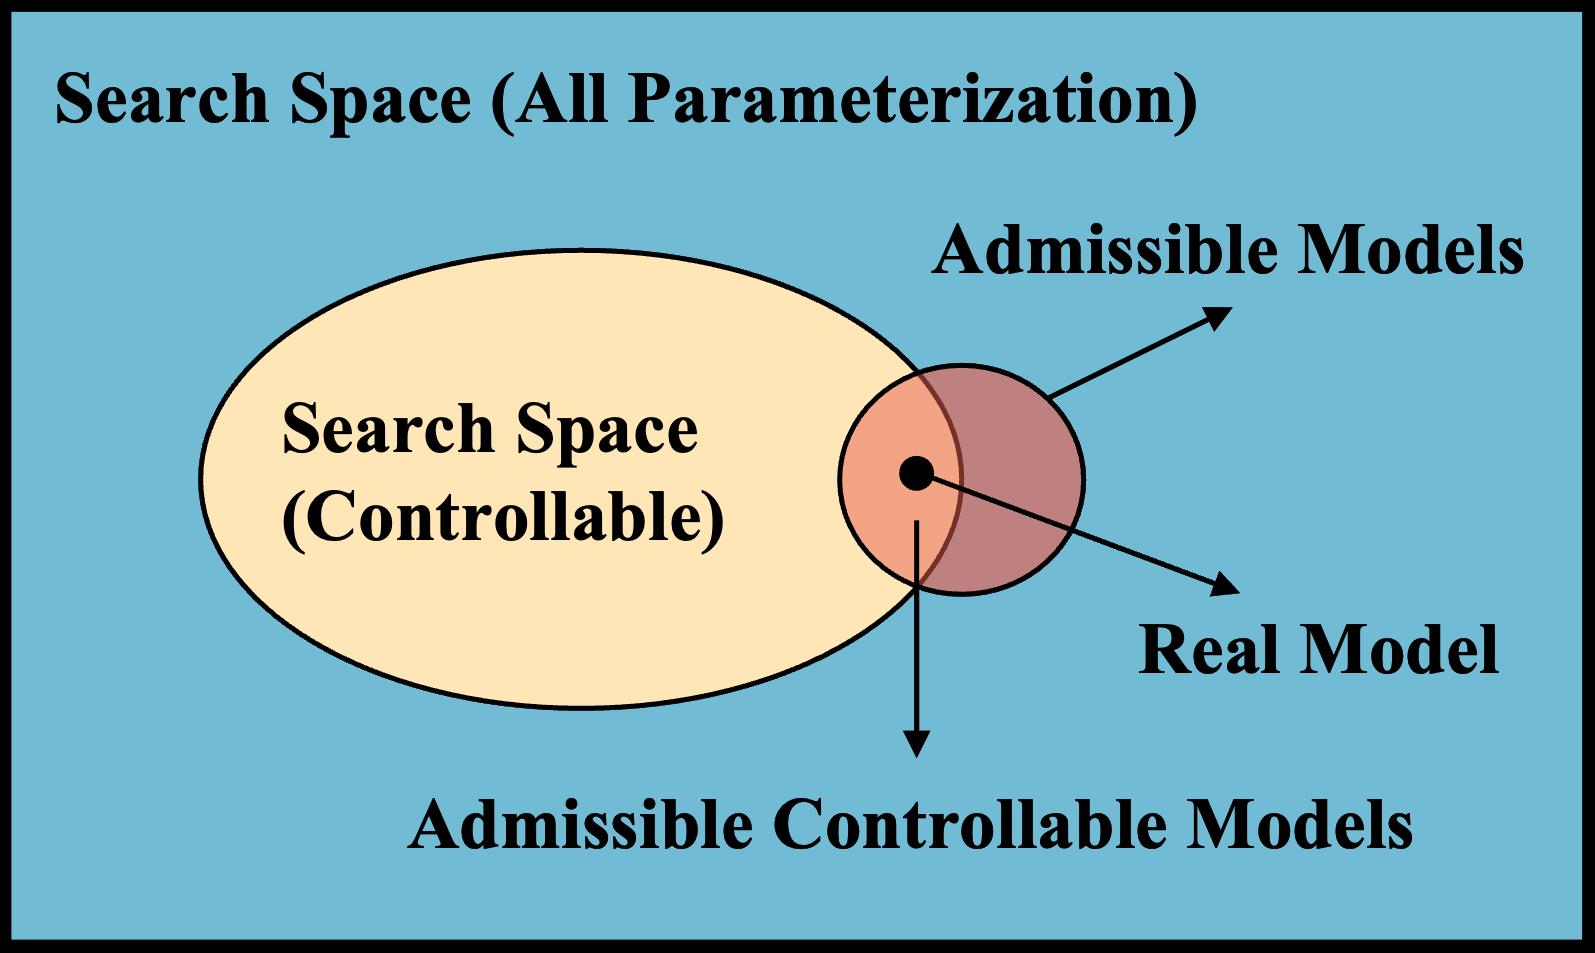
Learning Koopman Representations with Controllability Guarantees
The Fourteenth International Conference on Learning Representations, 2026
Scholar Published
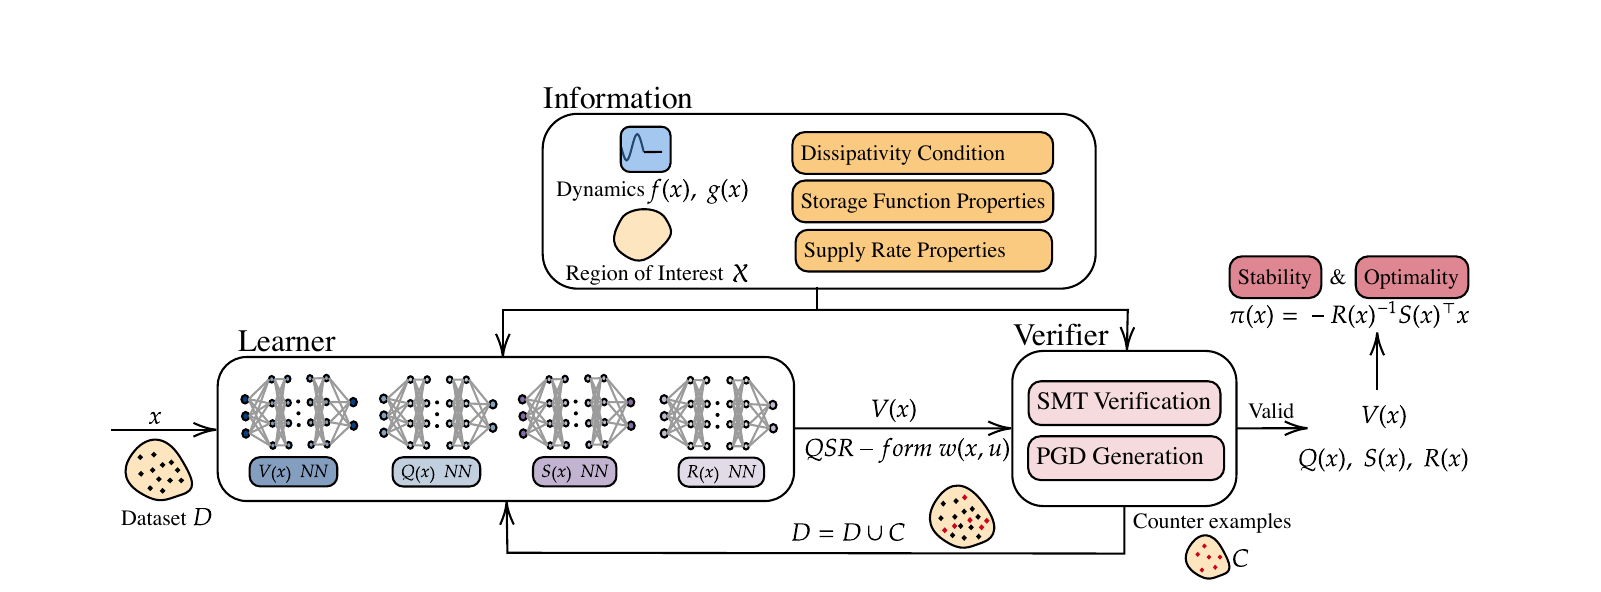
Designing neural controllers with optimality and stability guarantees by learning input-output dissipativity
Automatica 191, 113120, 2026
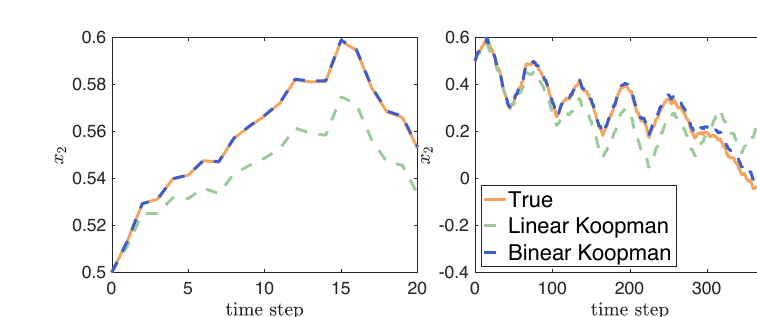
Data-enabled predictive control for nonlinear systems based on a Koopman bilinear realization
2025 IEEE 64th Conference on Decision and Control (CDC), 6498-6503, 2025
Scholar Published
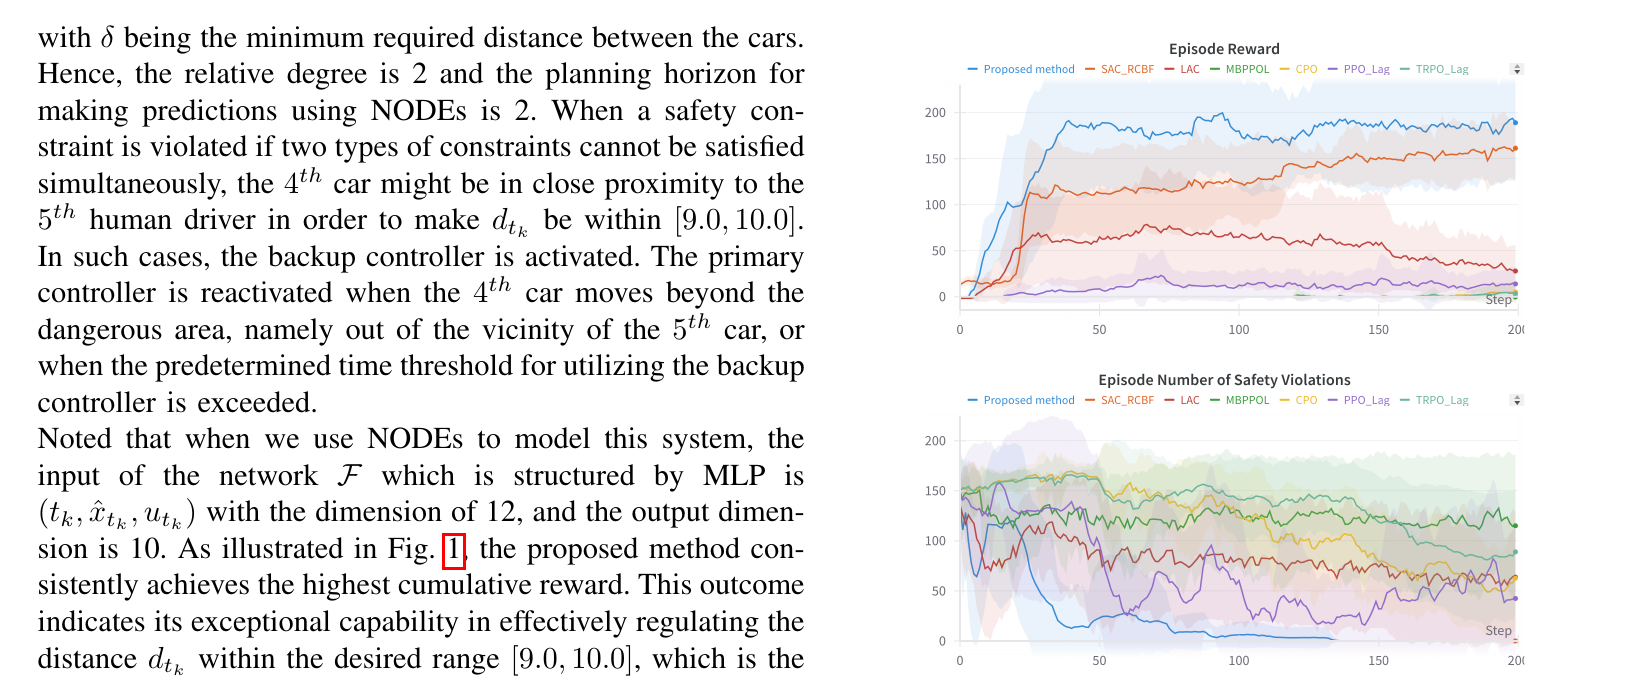
NLBAC: A neural ODE-based algorithm for state-wise stable and safe reinforcement learning
Neurocomputing, Volume 638, Article 130041, 2025
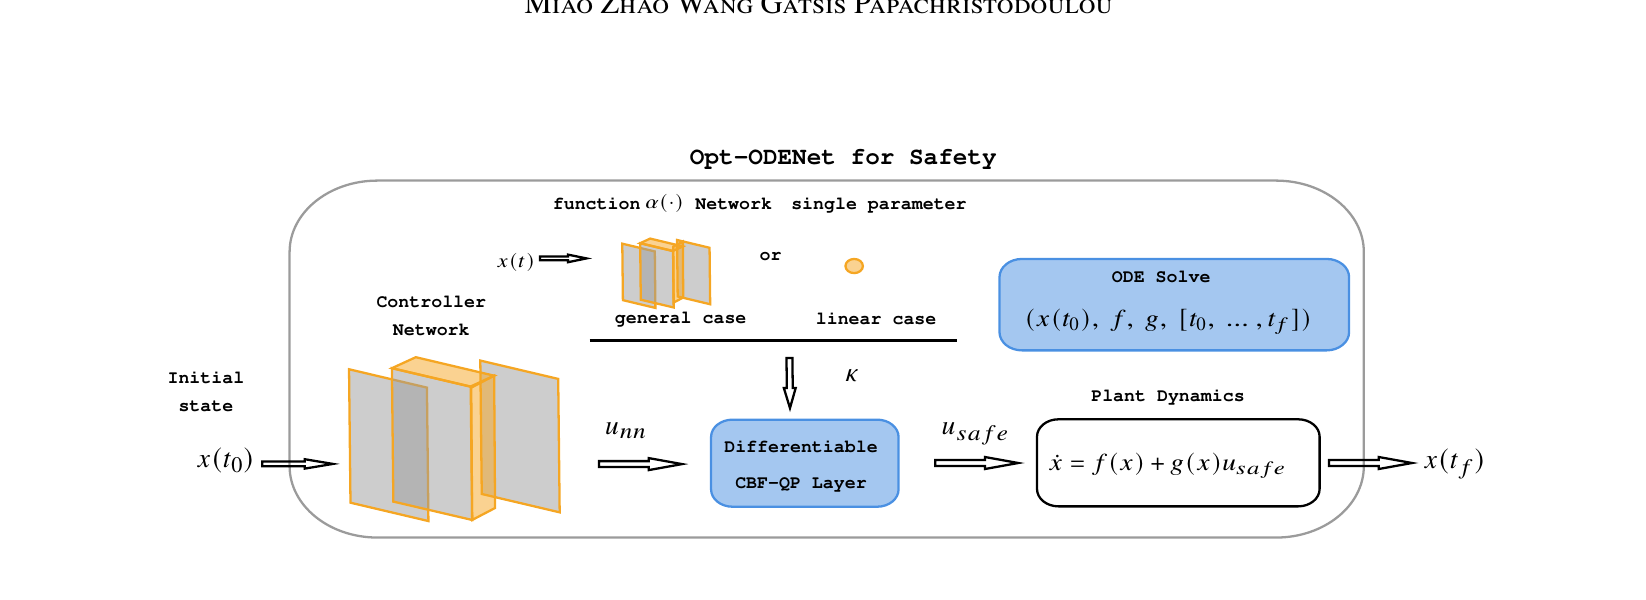
Opt-ODENet: Neural ODE controller design with differentiable optimization layers for safety and stability
Proceedings of the 7th Annual Learning for Dynamics and Control Conference, PMLR 283:1217–1229, 2025